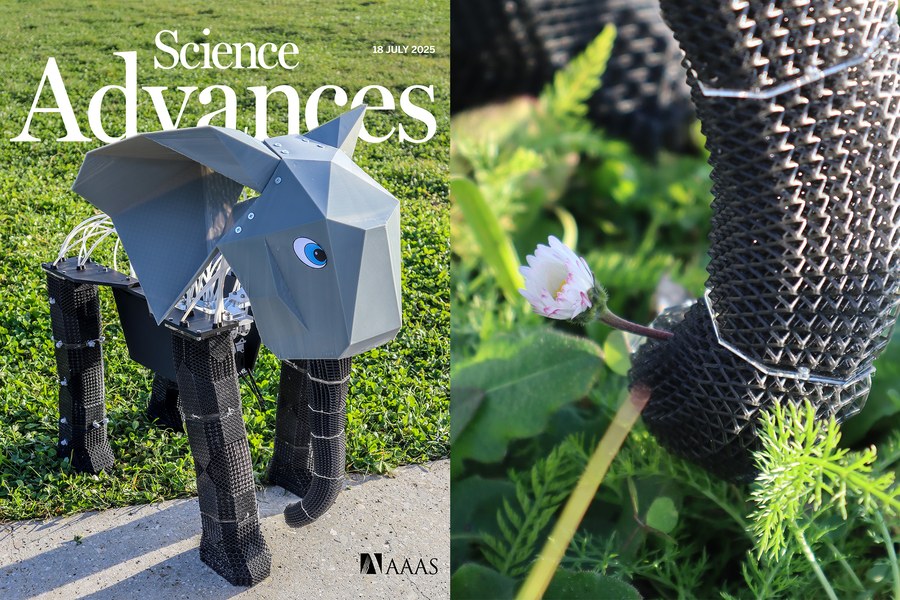
Soft robotics and materials
Meta-structures, soft actuators, and musculoskeletal robots with programmable morphology, co-designing geometry, stiffness and anisotropy for compliance.
Directions I am working on.
Meta-structures, soft actuators, and musculoskeletal robots with programmable morphology, co-designing geometry, stiffness and anisotropy for compliance.
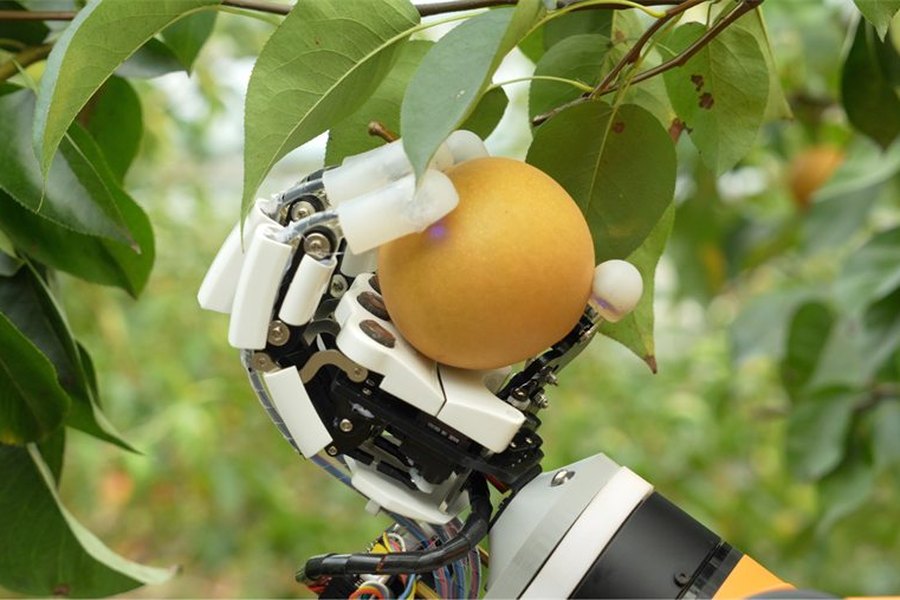
Tactile and biosensors that extend robotic perception beyond human and nature, from sensing mechanisms, to functional materials, then to flexible devices.
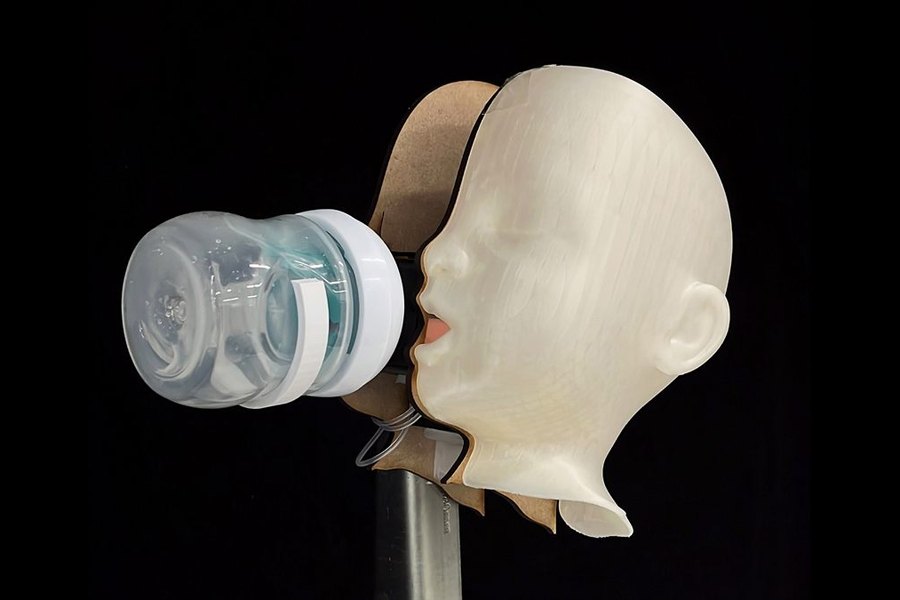
Translating principles from biology, anatomy, and physiology into robotics — from structural design to actuation/sensor integration and systemic control.
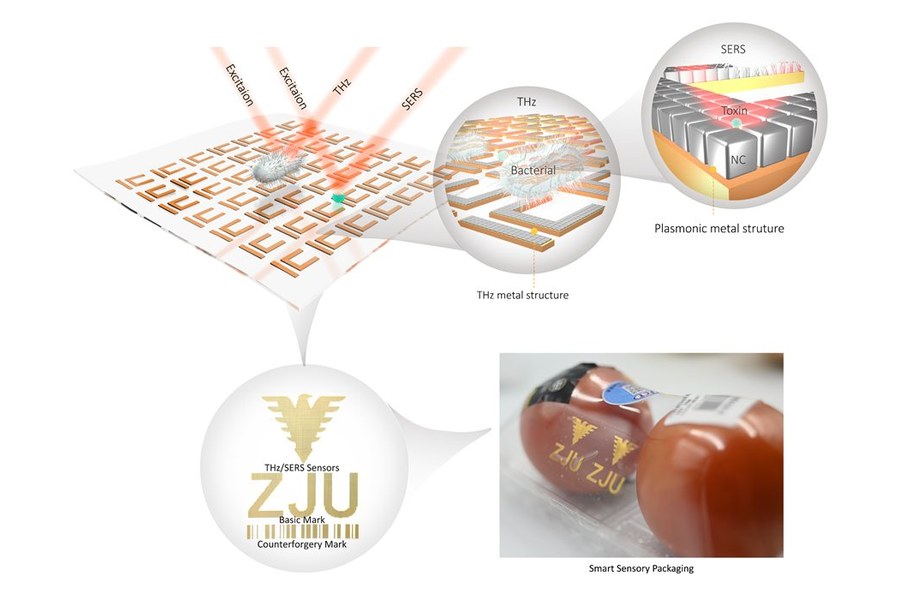
Robots as a scientific medium between human and food, including agricultural robots for in-situ detection and harvesting, as well as masticatory robots for food oral processing.
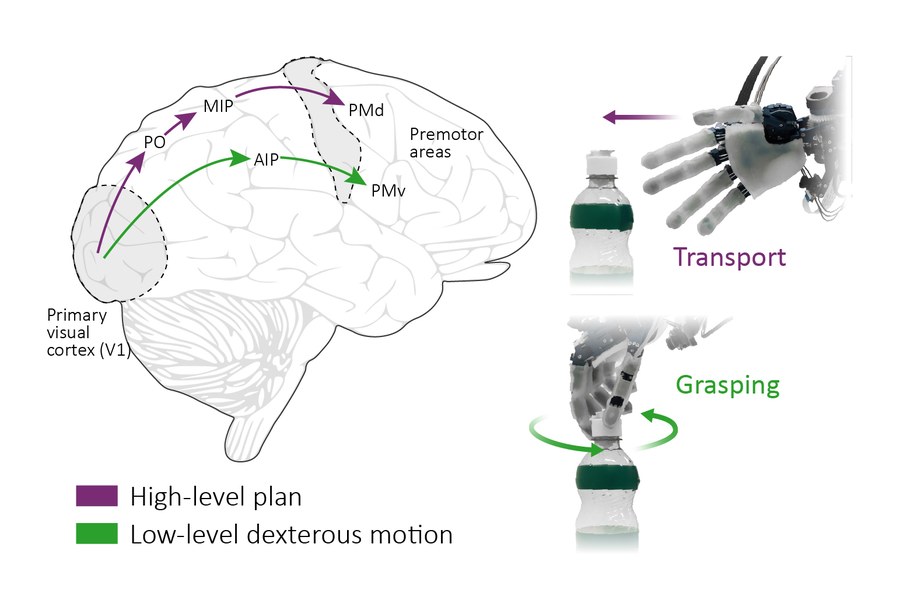
Exploring embodied intelligence, how body morphology, sensory capabilities and brain control jointly produce intelligent behaviour during interaction with environment.
New questions and cross-disciplinary collaborations are always welcome!
Related publications ↗